Course project · ETH Zürich · Spring 2026
Wall-E: a keyboard-typing robot
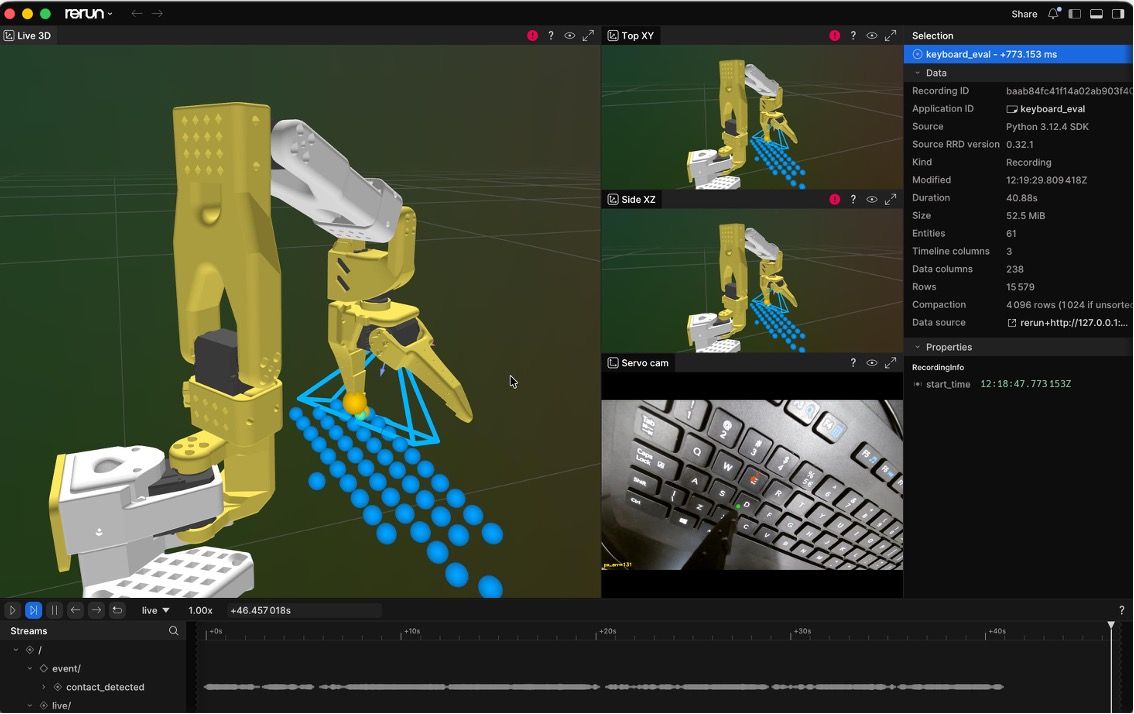
A robot that locates keys and types on a physical keyboard, built for ETH Zürich’s Robot Learning course. The project brought perception, motion planning, and control together on real hardware.
A fine-tuned YOLO model detects the keys, inverse kinematics translates their positions into arm movements, and PID control guides the key presses. Working with physical hardware meant debugging mechanical issues and connection failures alongside the software.
Team: Benedict Böttger, Niklas Britz, Peter Nutter, and Meghan Brandt.